元の投稿を読み込み中…X で見る ↗
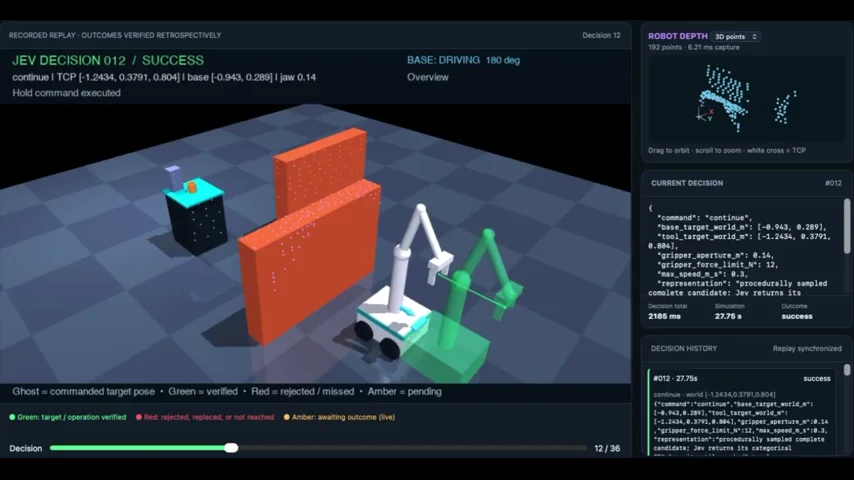
A hierarchical LLM pipeline drives a MuJoCo robot arm through parallel observe-interpret-generate-compare calls over depth maps, contacts and joint states, selecting collision-screened numerical commands executed via deterministic IK—navigating barriers and lifting a cup in one trial.
元の投稿
元の投稿を読み込み中…X で見る ↗
jev
キーワードを入力してユースケースを検索。