正在加载原动态…在 X 上查看 ↗
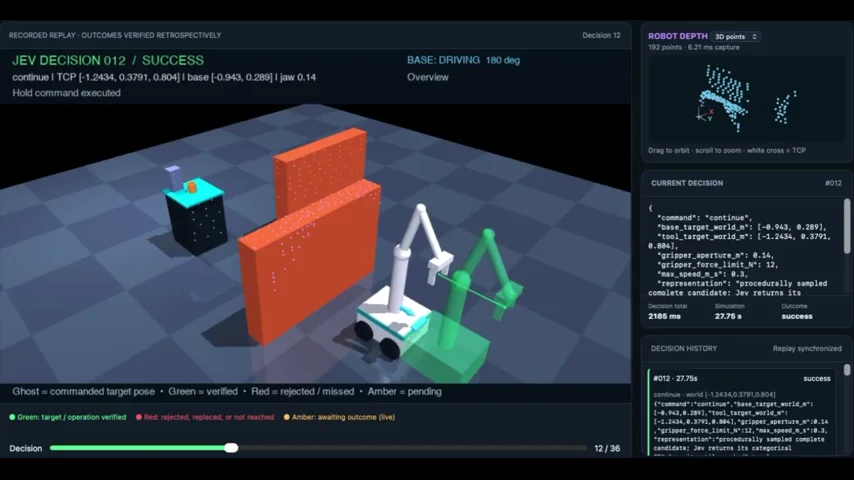
A hierarchical LLM pipeline drives a MuJoCo robot arm through parallel observe-interpret-generate-compare calls over depth maps, contacts and joint states, selecting collision-screened numerical commands executed via deterministic IK—navigating barriers and lifting a cup in one trial.
原始动态
正在加载原动态…在 X 上查看 ↗
jev
输入关键词以查找应用案例。