37 个案例
现实与机载控制
机械臂
13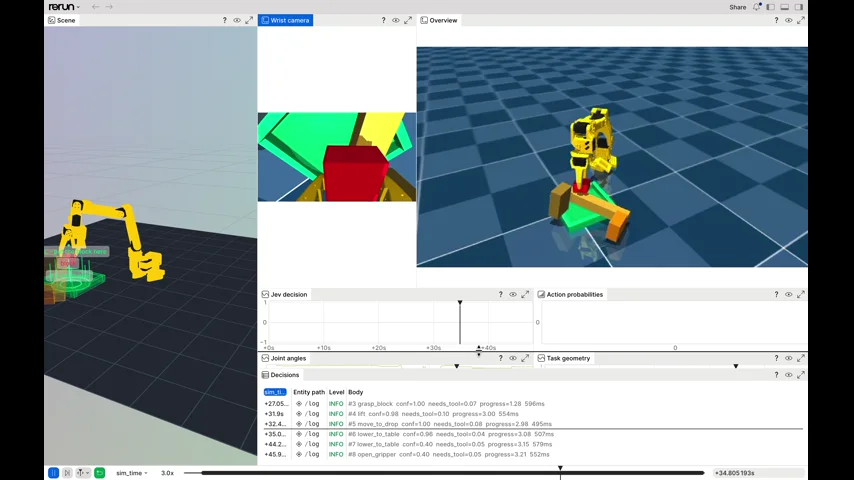
A robot-arm agent autonomously improvised tool use—grabbing a hook to drag an out-of-reach cube within range before completing the pick-and-place—running fast enough for real-time robot control.
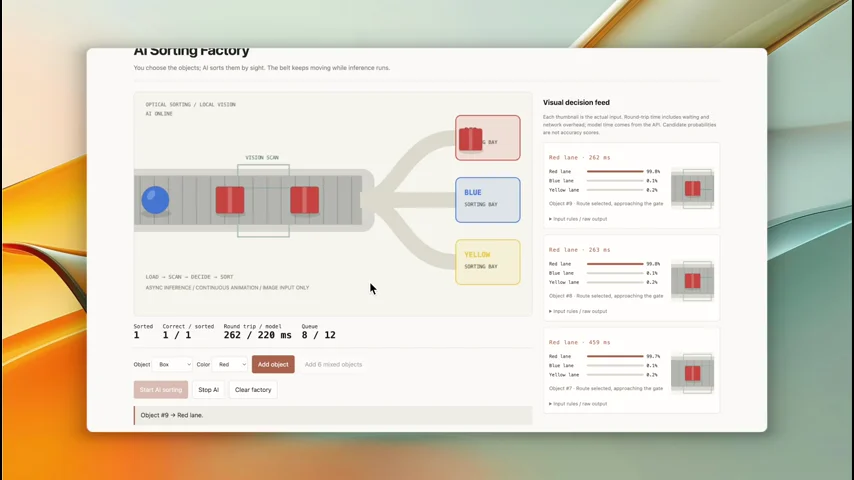
Local "Jev"-style vision inference hack: maps candidate outputs to fixed labels, prefills then samples with capped tokens, running a 4-bit multimodal Qwen-3.5-0.8B on a 16GB M4 MacBook Pro to perform three-color item sorting in 200ms.
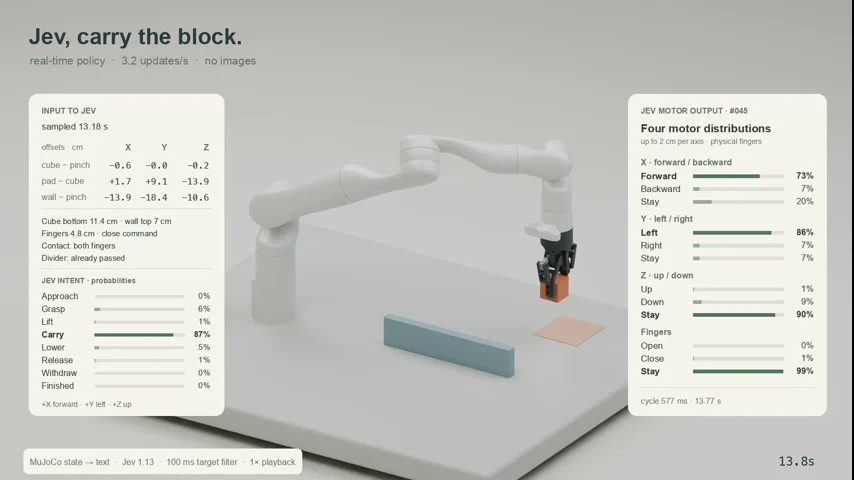
A text-only LLM acts as a real-time MuJoCo robotics policy, splitting each control update into two calls — first deciding the next action, then computing arm and gripper motion from geometry and contact inputs instead of images.
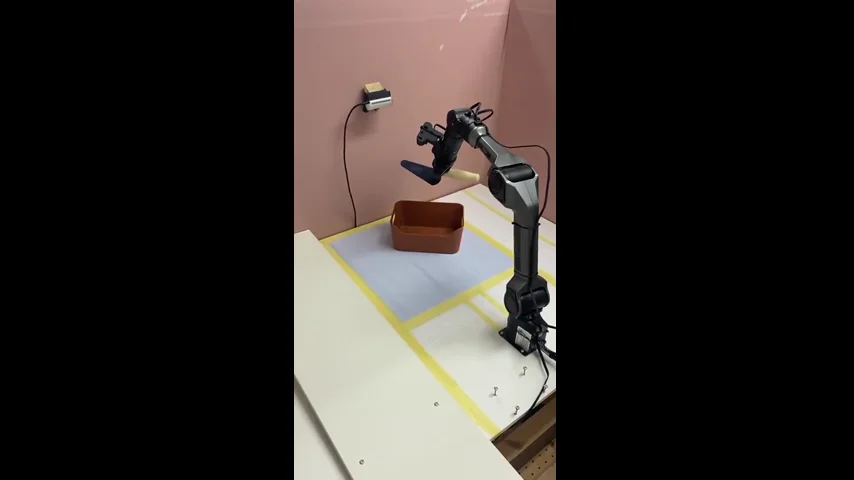
Two LLM agents (Jev vs. GPT-6 Astra) drove a real Agilex PiPER robot arm through a skill-pick → governor-check → actuate loop, and the 8 open-sourced notebook runs reveal an unexpected speed gap between the models.
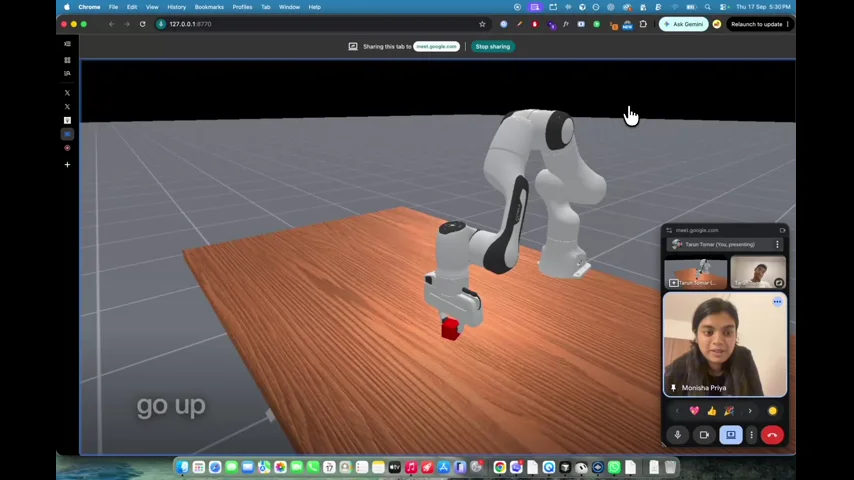
A zero-shot robot-arm demo turns plain-English goals into chained hardcoded motion primitives via an API, executing tasks without any training.
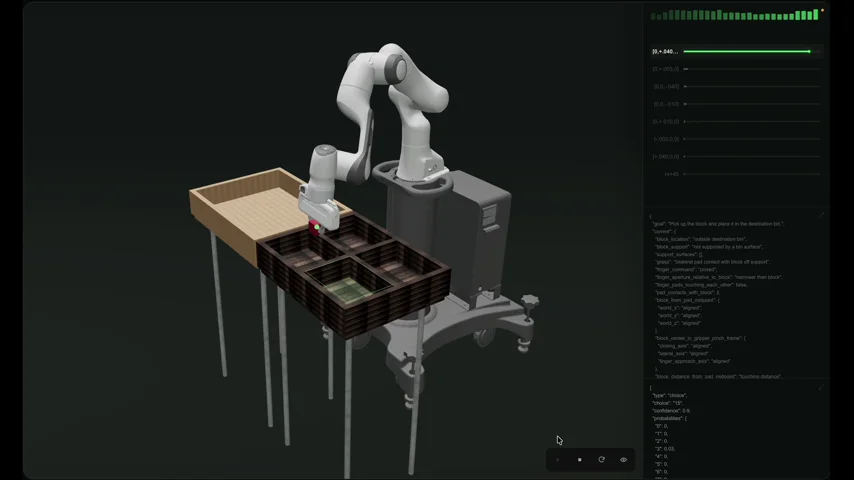
A spatial-reasoning AI agent successfully placed a cube into the correct bin blind — using only geometry, contact feedback, and available controls with no image or scene description — showcasing zero-shot robotic manipulation potential.
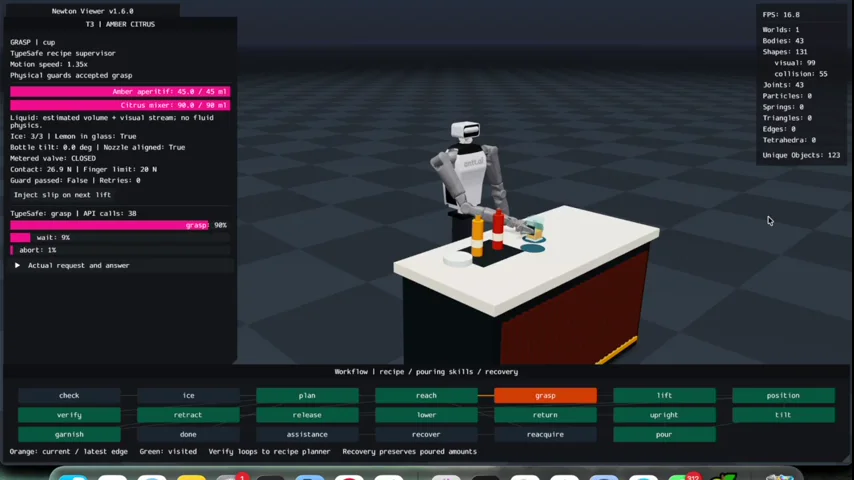
Jev runs a multi-stage manipulation task where an agent handles high-level task transitions and confidence gating at each boundary while deterministic physics guards manage execution, demonstrating reliable agentic control.
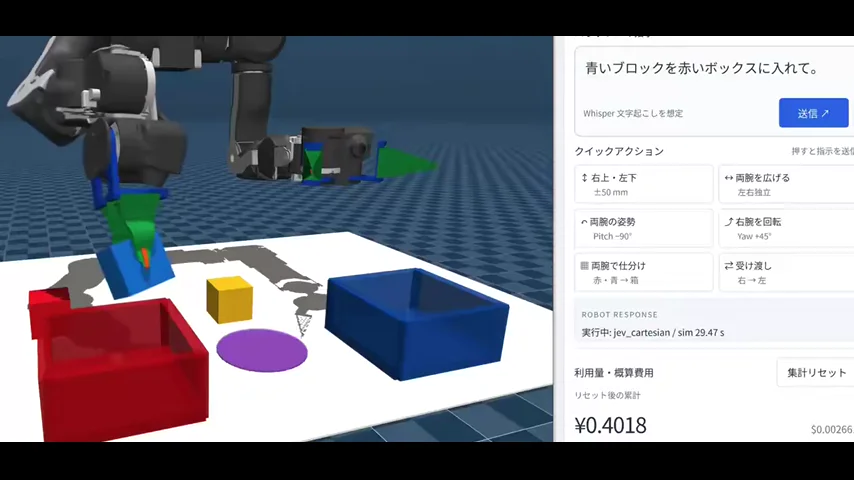
A dual-arm robot that autonomously decides its actions using Jev, a typed AI embedded in the robot's decision layer while IK and physics run in code — responding in 500ms at 0.5 yen per trial with schema-typed outputs.
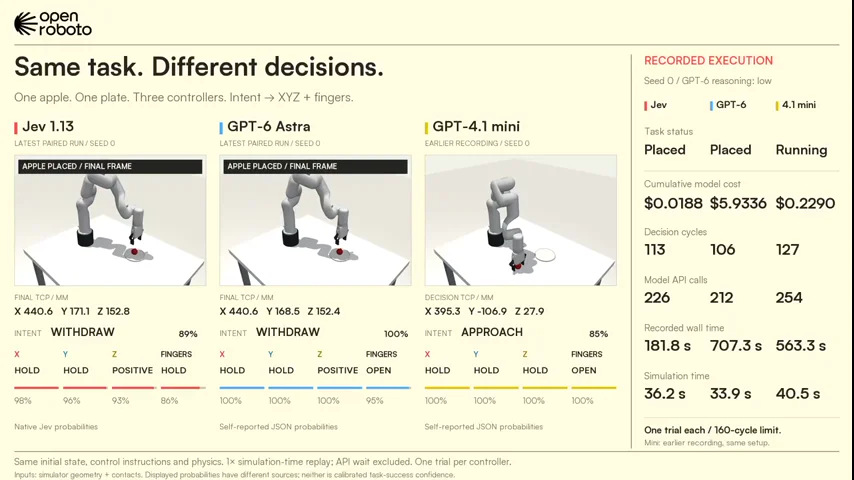
Jev, a robot-control model, was benchmarked in MuJoCo against GPT-6 Astra and GPT-4.1 mini on an apple-to-plate task where each model outputs an intent plus X/Y/Z arm direction and gripper open/hold/close commands.
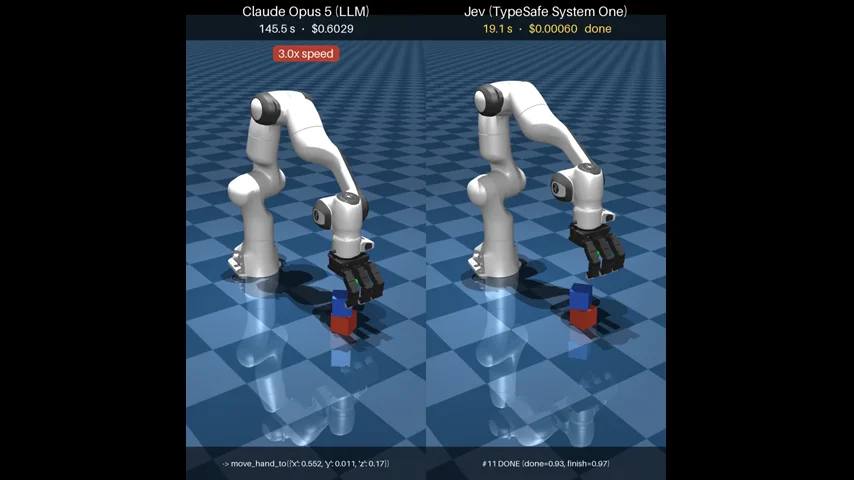
A robotic box-stacking demo shows a fast "System One" typed-decision model finishing the task in 19.1s for $0.0006—roughly 8x faster and ~1250x cheaper than Claude Opus 5, which took 158.8s at $0.75.
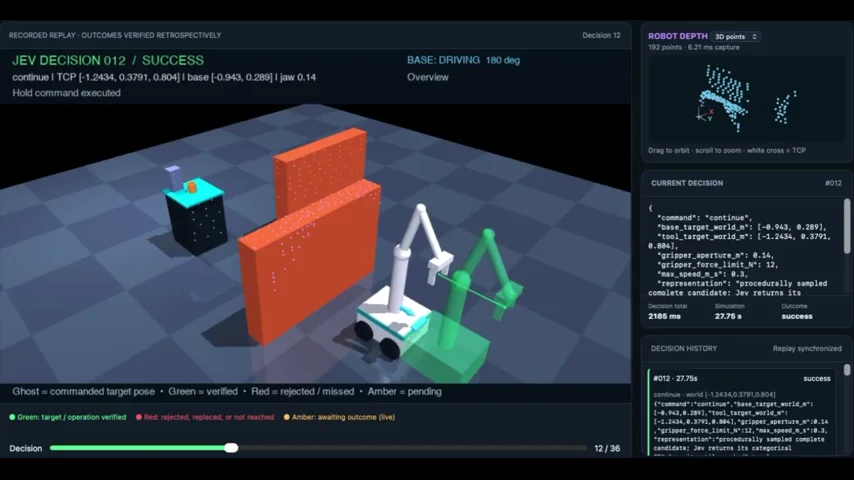
A hierarchical LLM pipeline drives a MuJoCo robot arm through parallel observe-interpret-generate-compare calls over depth maps, contacts and joint states, selecting collision-screened numerical commands executed via deterministic IK—navigating barriers and lifting a cup in one trial.
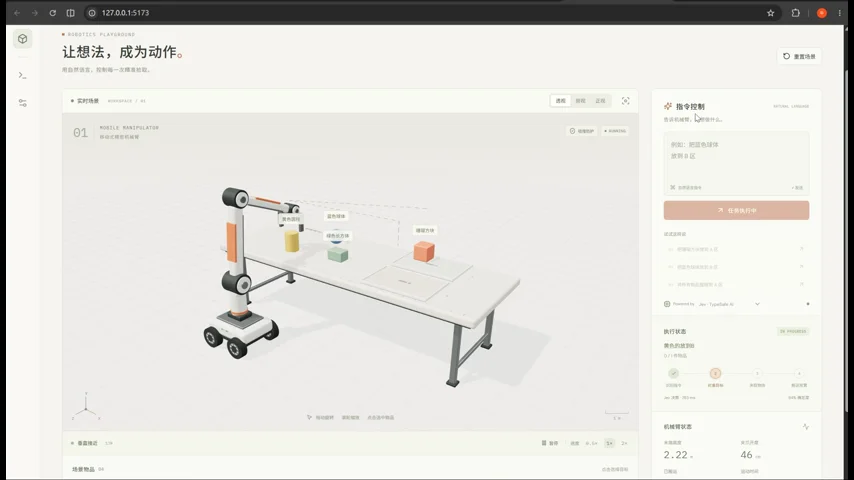
A robotic arm executes tasks from plain-text instructions via TypeSafe jev's decision-making, with its kinematics control algorithm and modeling generated by GPT-6 Astra, delivering notably fast motion response.
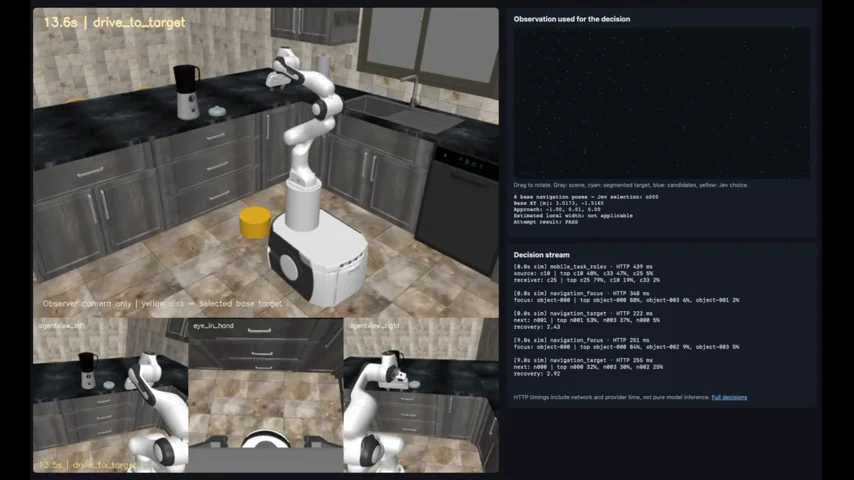
SAM 3 + depth cameras feed 3D observations to parallel Jev calls that rank sampled grasp/placement poses, while deterministic IK controllers drive a simulated mobile robot through a nearly complete lid pick-and-place sequence.
自主运载
24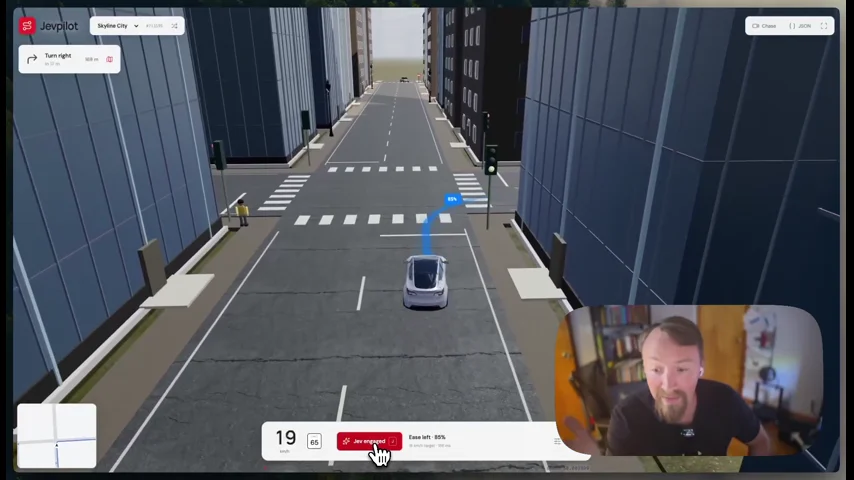
Tesla Full Self-Driving was rebuilt from scratch in under an hour using a single model, a claimed major unlock for rapid autonomous driving development.
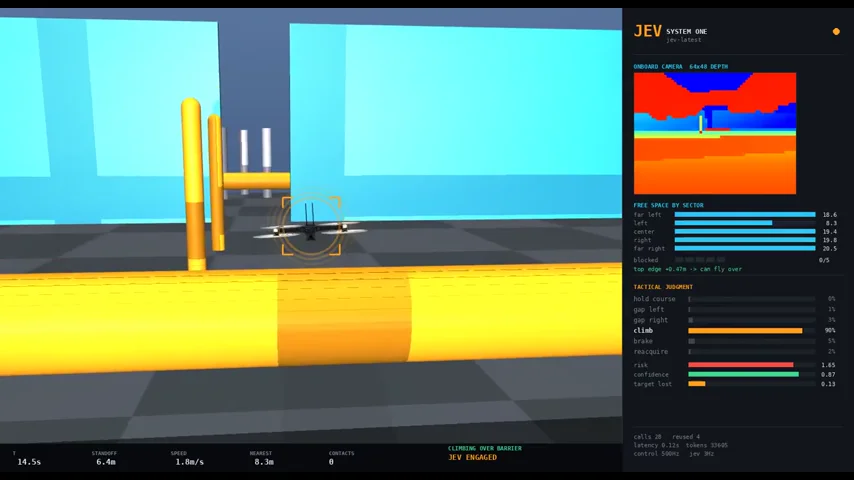
Jev built a working drone application demo in just 15 minutes for $0.10, showcasing fast, ultra-low-cost prototyping for autonomous vehicle applications.
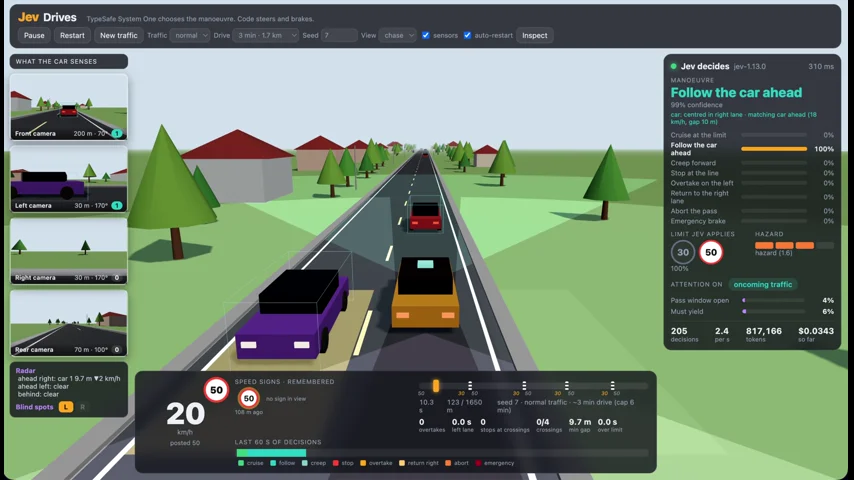
A self-driving car simulator demo where a typed "System One" LLM ingests structured sensor state and emits typed driving decisions—steer, brake, overtake—while handling pedestrians and speed limits, now publicly accessible via prompt.
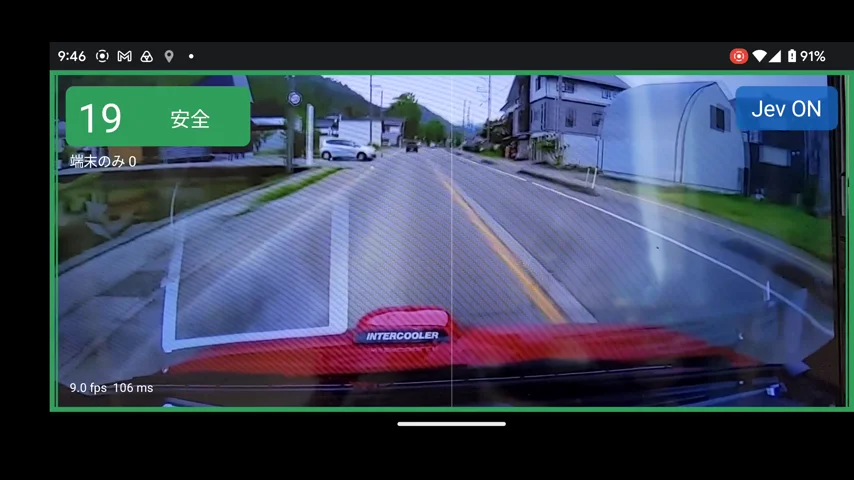
A camera-based driving hazard-prediction app built with jev was prototyped and tested on YouTube footage, but detection accuracy fell short of expectations, prompting plans to study the domain further.
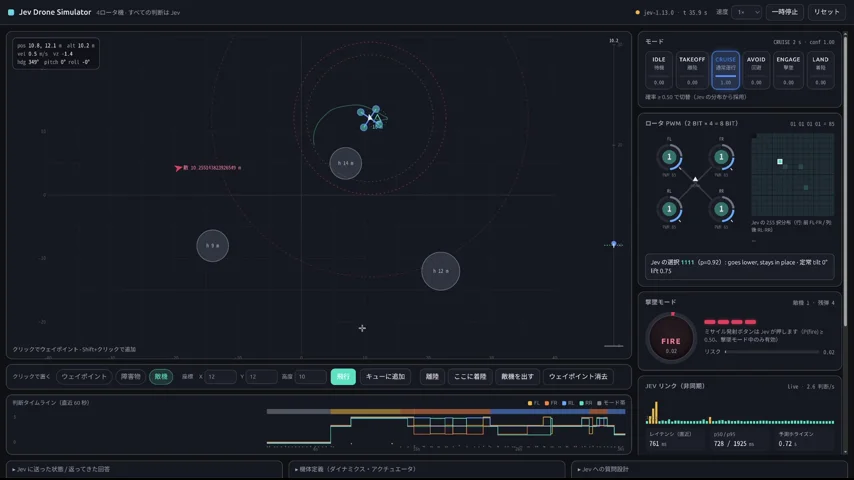
A hackathon-built drone simulator where Jev autonomously switches flight modes (hover, takeoff, obstacle-avoid, kill), decides missile firing, and controls four rotors at 2-bit resolution—burning ~$1 per tens of minutes via its high-frequency decision loop with noticeable latency.
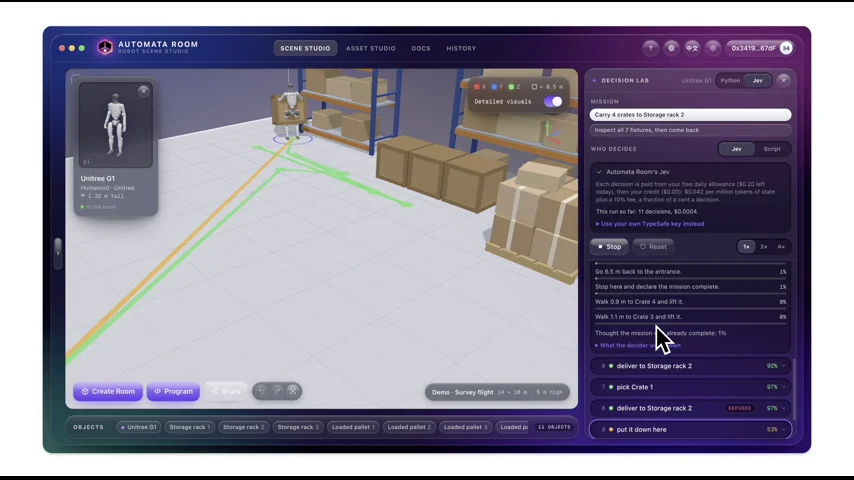
An AI agent serves as the decision-making brain for a Unitree G1 humanoid, autonomously planning and executing a multi-trip crate-carrying task—hauling 4 crates to a storage rack one at a time then returning to base—scored on trip efficiency.
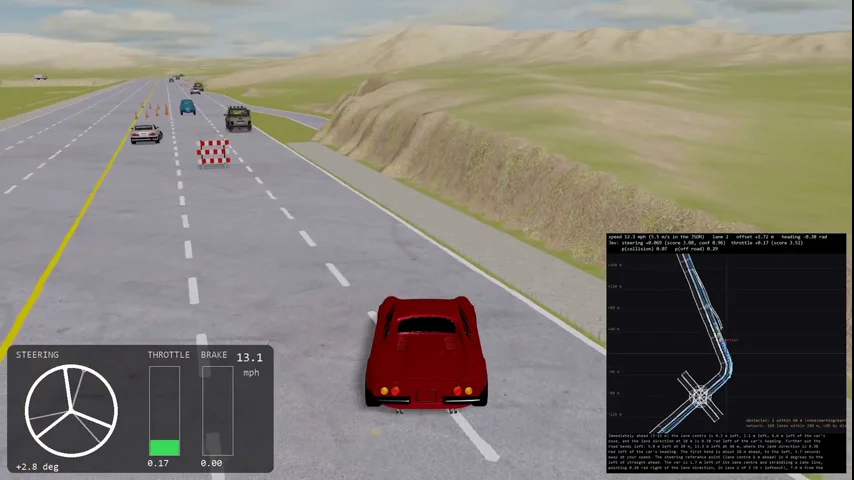
JEV controls a driving simulator's raw vehicle inputs in true realtime, making decisions fast enough to steer a continuously moving car with no pauses while it "thinks" — not just rendering 50ms-per-step actions into a fake realtime video.
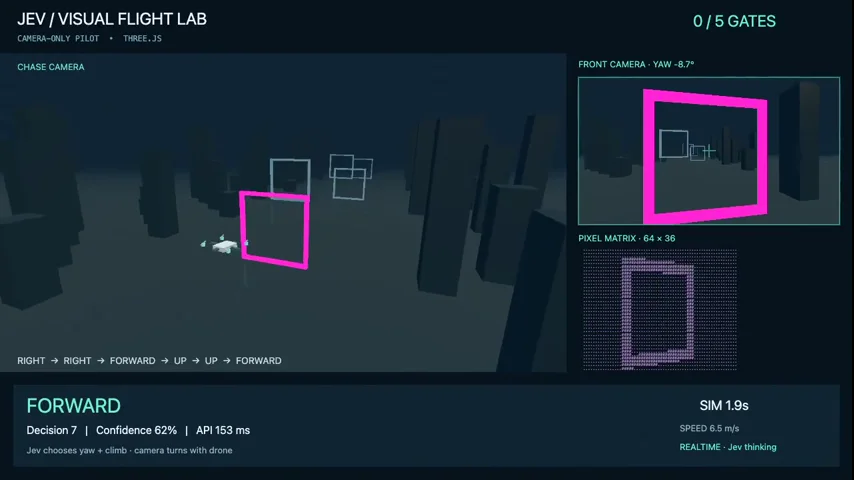
An AI agent autonomously flies a drone, demonstrating agentic control of a real aerial vehicle with no human piloting required.
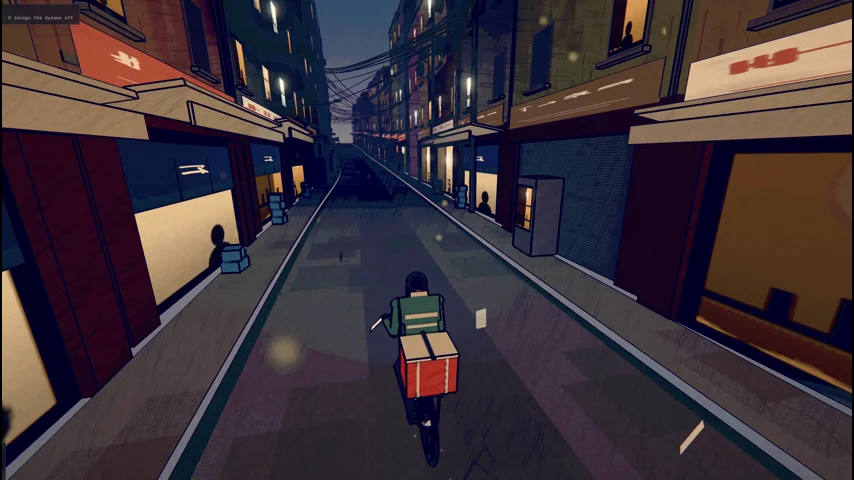
A full-self-driving stack retrofitted onto an ordinary bicycle attempts autonomous steering but struggles to hold a straight line.
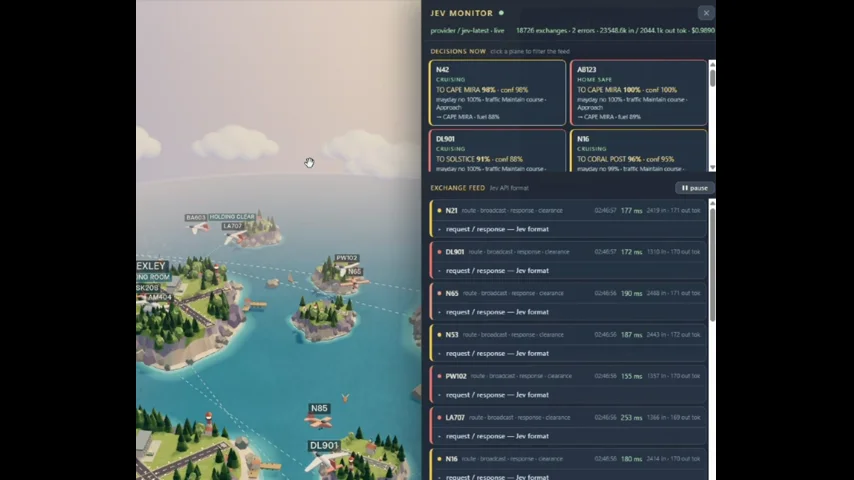
Jev, a new state-aware model architecture, autonomously directs airplanes in a small-scale simulation with sub-300ms decisions, beating Luna while promising machine-grade tool-call accuracy at near-unmeterable inference cost.
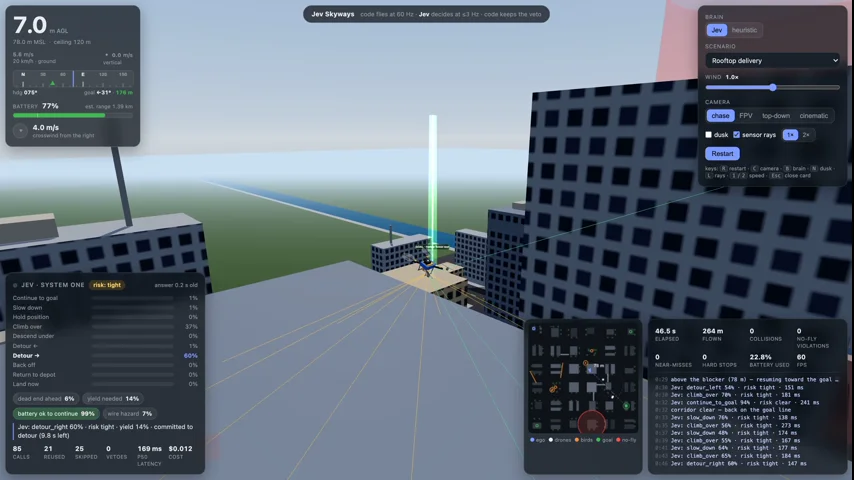
I'll try resolving the t.co link to see what the demo actually is.
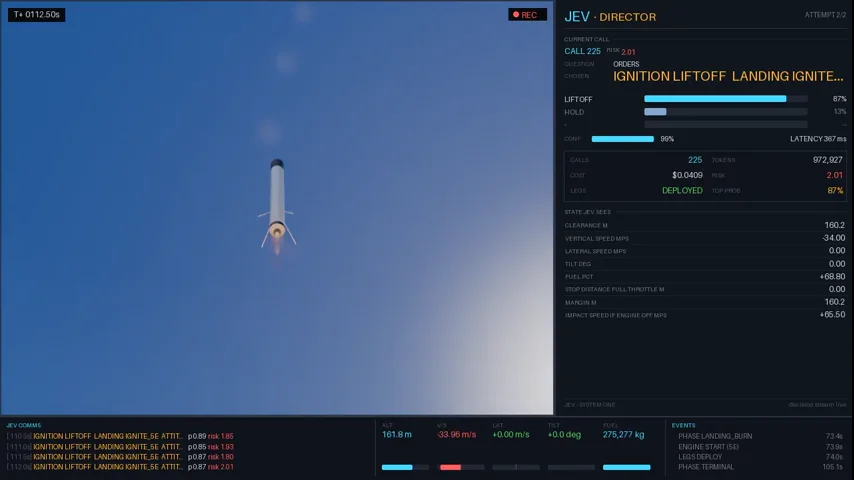
An LLM autonomously piloted a simulated Falcon-9-class booster through full launch-to-landing in MuJoCo—with real atmosphere, Mach-dependent drag, wind, and propellant depletion—making ~1Hz control decisions (engine count, burn timing, legs, touchdown) with no autopilot or safety veto, landing after 12 runs for just 245 calls and $0.04 in API costs.
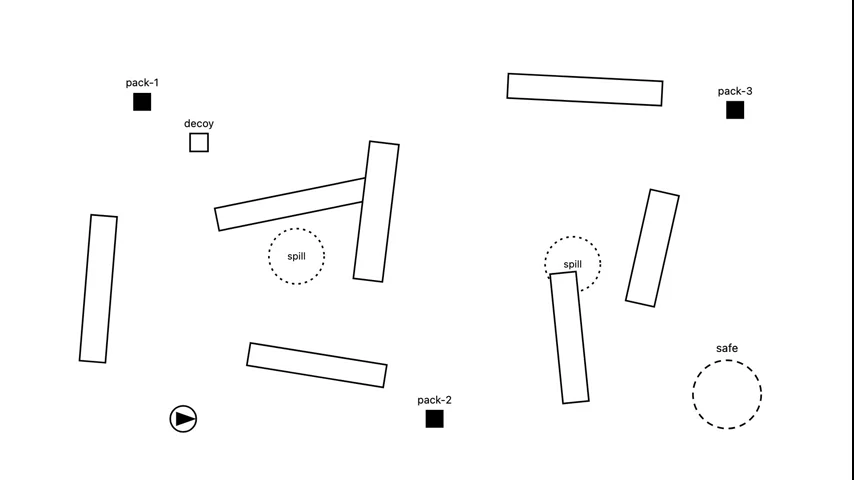
An autonomous robot navigates a warehouse environment to deliver packages to designated safe zones while avoiding spills, but struggles with harder scenarios involving complex spill patterns and intricate wall structures.
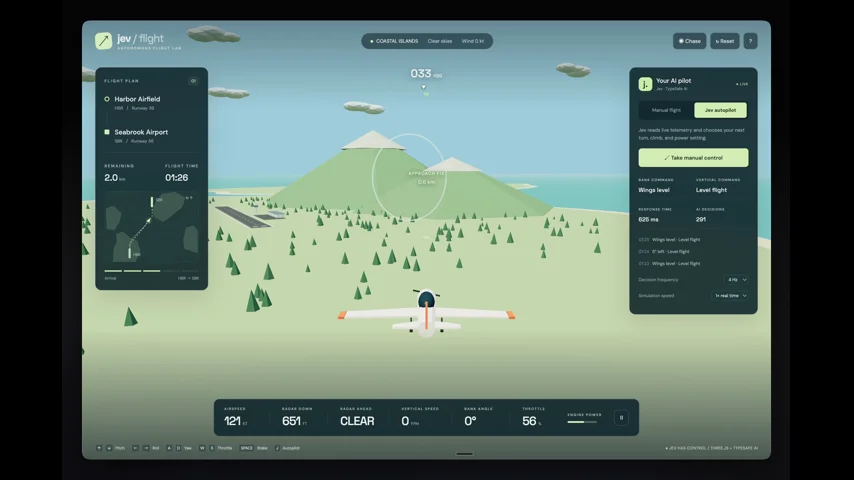
Jev, an AI agent, autonomously pilots a simulated aircraft end-to-end—handling takeoff, waypoint navigation, terrain avoidance, and safe landing using full access to live flight telemetry.
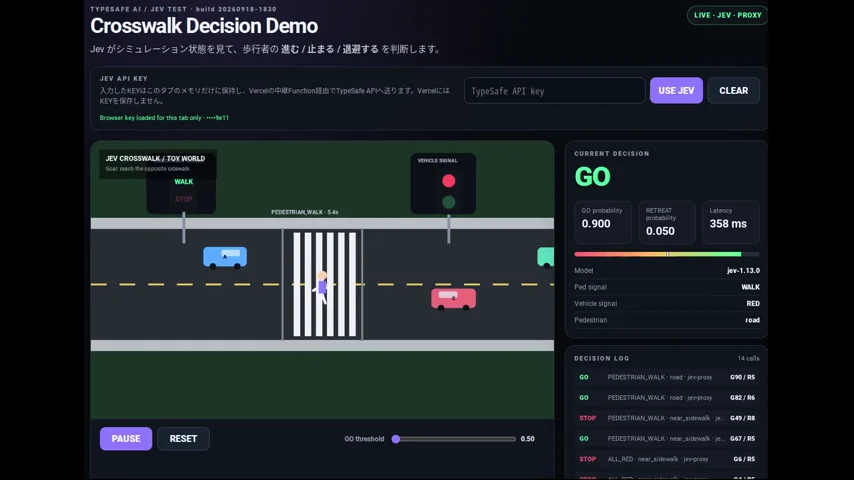
A demo shows the Jev robot autonomously navigating a signalized crosswalk by observing oncoming traffic to decide when to move or stop, successfully crossing to the other side — though with some nerve-wracking moments.
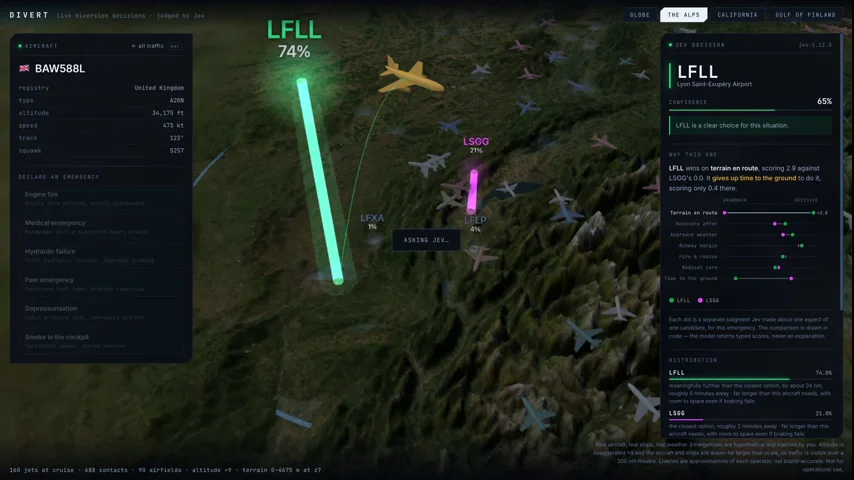
What happens when you let @typesafeai’s Jev choose where a burning cargo ship should go, or where a plane in trouble should land? I built an app to find out. The ships and aircraf
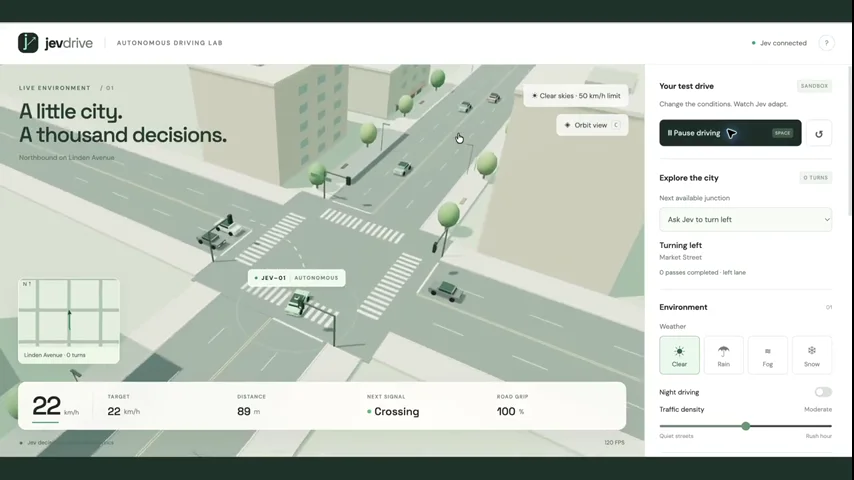
A prototype autonomous driving simulator built on TypeSafe AI's Jev model, visualizing the model's real-time driving decisions for the car at every point in a corner overlay.
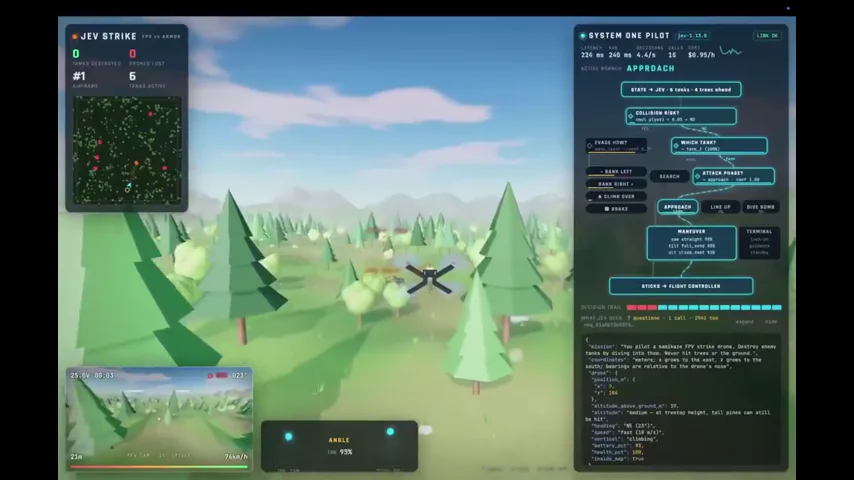
A demo video shows JEV autonomously controlling drone flight, showcasing end-to-end vision-to-flight navigation without manual piloting.
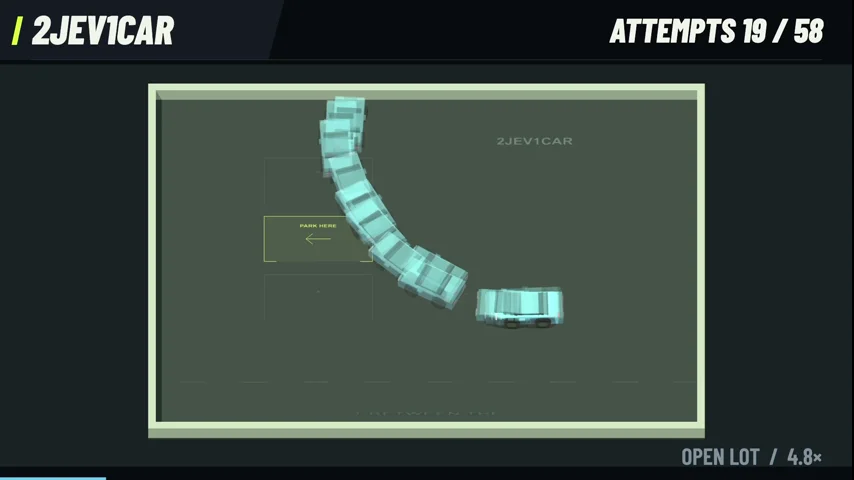
Two autonomous agents cooperatively park a car in an open lot — one steering, one controlling pedals — succeeding after 59 attempts.
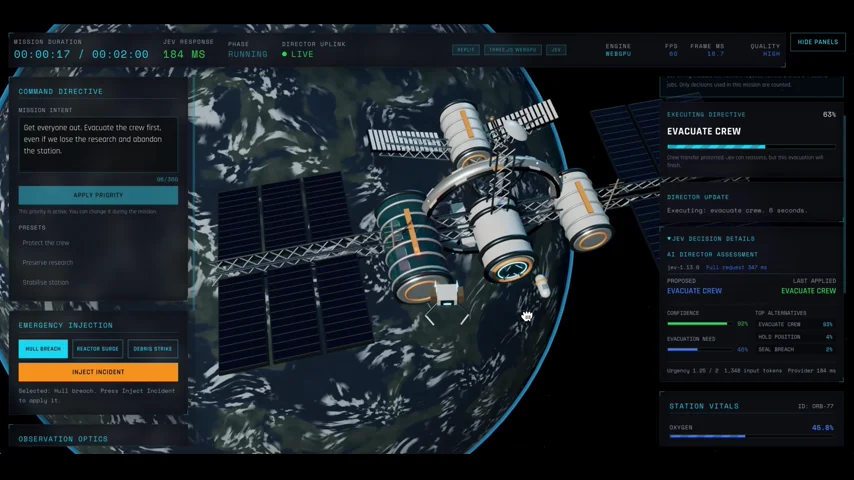
A WebGPU-native demo where Jev autonomously assesses a space station scenario, weighs evacuation risk and urgency, and directs drone rescue actions at 208 ms average response including network latency, rescuing all 12 crew.
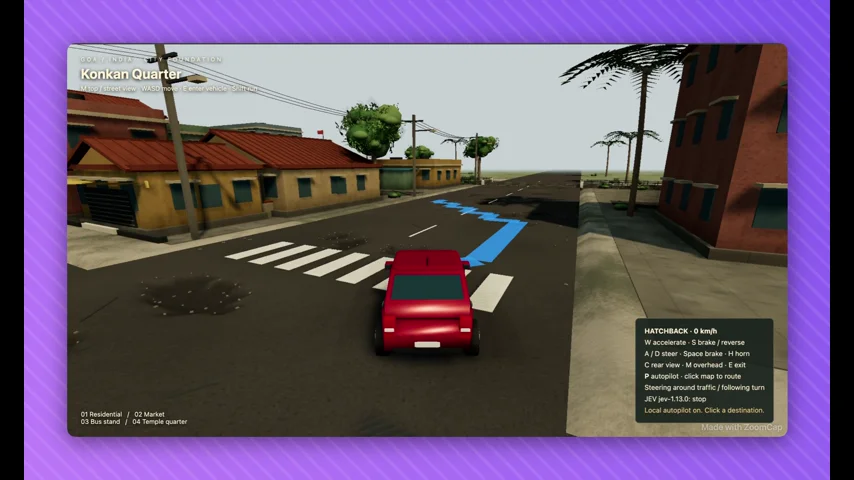
An AI agent plugged into a driving game navigates city traffic autonomously — stopping for pedestrians and crossing cars, slowing for corners and potholes — making stop/yield/slow/proceed decisions while local code handles steering and collision checks, with a live status HUD, all for $0.0208 per city drive.
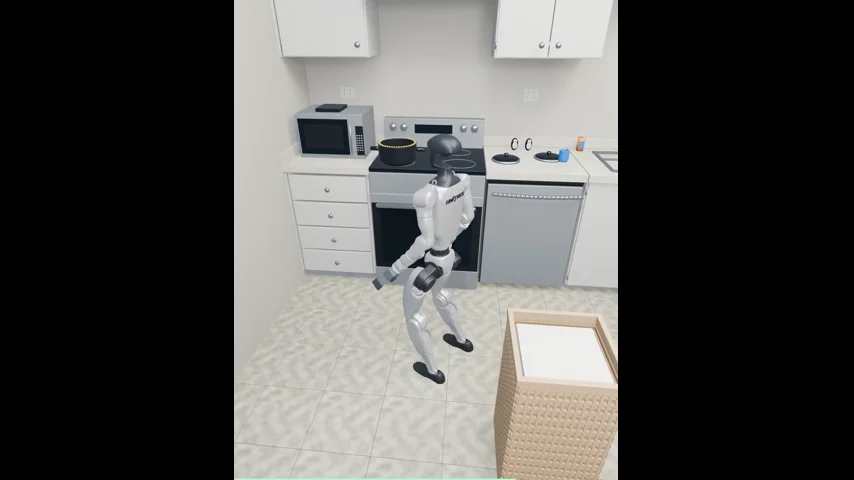
TypeSafe's JEV drove a G1 humanoid through a virtual kitchen—VLM+depth mapping, a path planner proposing routes, JEV picking moves, and a pretrained walking policy—reaching the stove past obstacles in ~64 seconds of simulation.
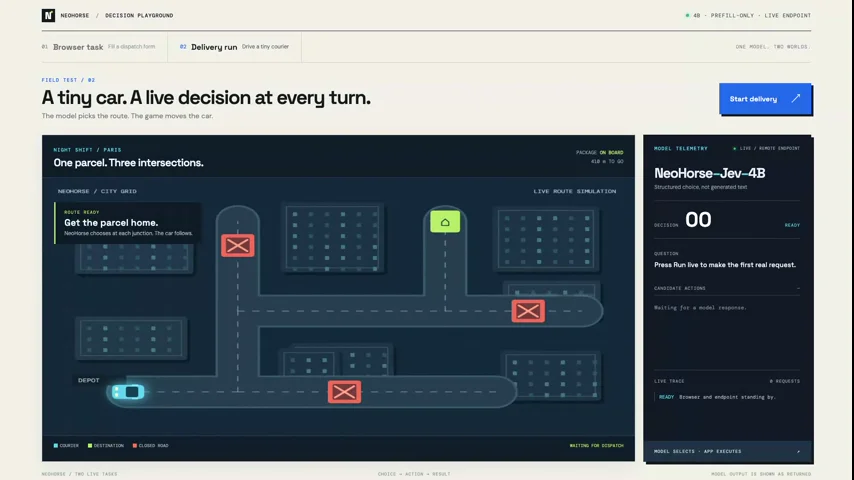
NeoHorse-Jev-4B, a 4B system-1-style model, drives a delivery car agent by emitting single-token-style turn decisions (north→east→north) per junction from road state + valid turns—delivering the parcel with a tight decide→act loop instead of 500-token reasoning monologues.
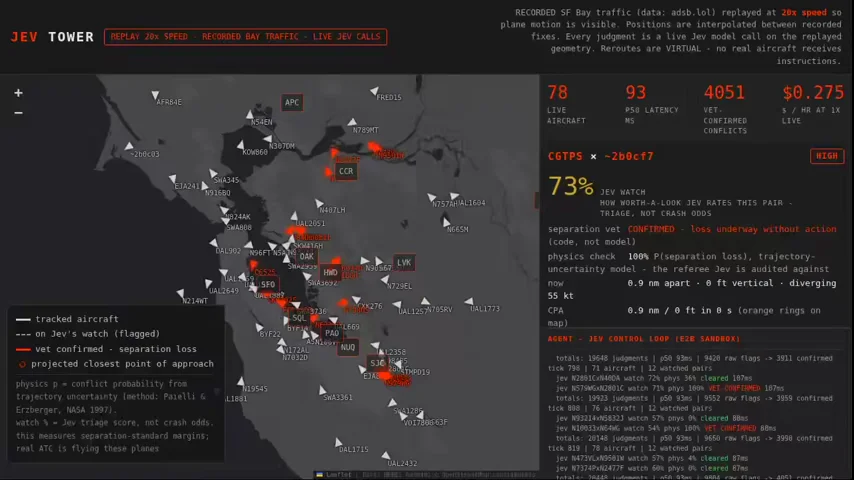
A real-time air traffic control agent monitored 900 live Bay Area flights inside an e2b sandbox, judging every risky flight pair in 103ms with zero missed conflicts — while GPT-4o missed 56 and Opus 5.5 needed 12s just to reach zero.